


Junior Computer Vision / AI Engineer · Perception · Robotics Software · Edge AI
I build and evaluate computer vision pipelines, drawing on an automotive perception internship and academic C++ / ROS robotics work. My projects cover data preparation, inference, failure analysis and deployment verification.
Based in Germany. Available for full-time junior engineering roles and open to relocation to Dubai, Abu Dhabi and the wider UAE.
From road images to an inspectable inference service. A YOLOv8n pipeline for four road-damage classes: validated RDD2022 data preparation, training and evaluation, FastAPI image inference, ONNX export verification and CPU benchmarking.
Stack: Python · PyTorch · OpenCV · ONNX Runtime · FastAPI · Docker
Repository · 60-second demo · Model card & evidence · Error analysis
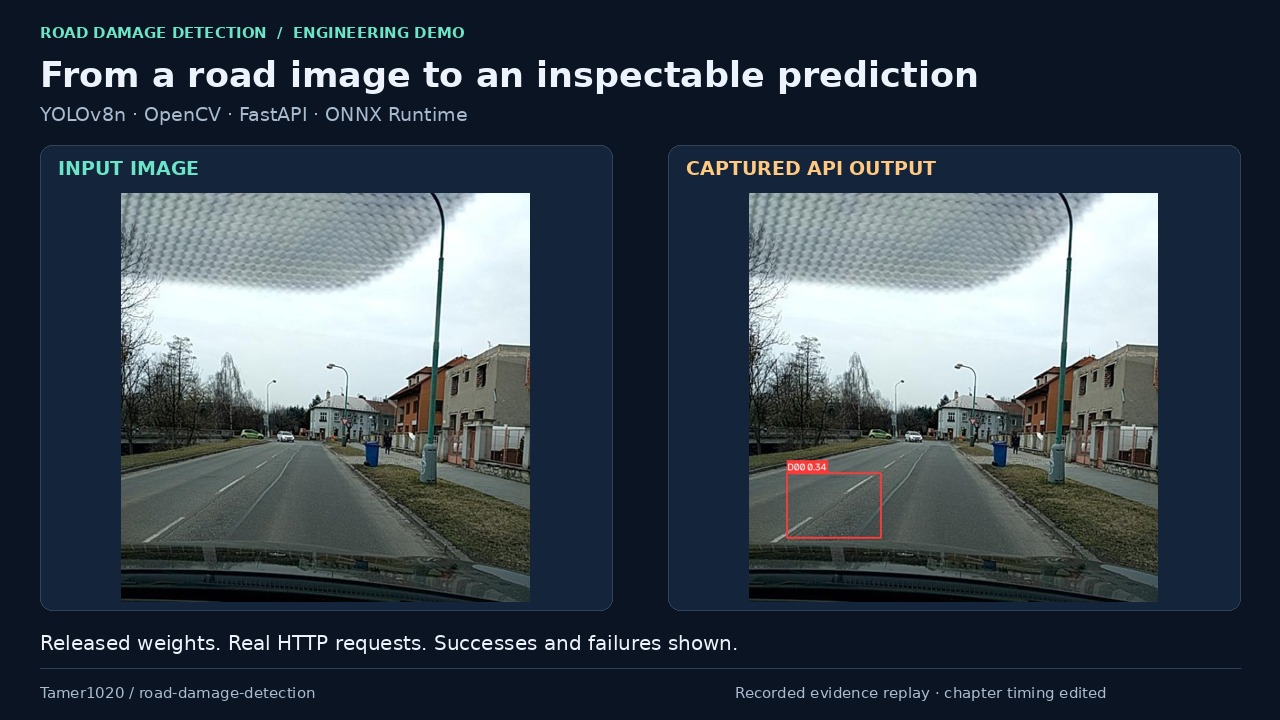
Demo replays real HTTP responses from the released model, including successful detections and failure cases. Chapter timing is edited.
- Historical validation: 24.5% mAP@50 and 34.0% recall on 565 RDD2022 Czech validation images.
- Historical CPU benchmark: 21.466 ms mean latency, 2.76× lower than PyTorch CPU, on an Intel i7-13650HX. Ten images, 100 timed calls; image decoding excluded.
- Current engineering checks: 62 unit/contract tests, plus real-weight PyTorch/ONNX verification and HTTP smoke checks in CI.
Export agreement checks backend consistency, not detection accuracy. Independent route/country validation and embedded-device performance remain unmeasured.
Camera-quality diagnostics for perception pipelines. An OpenCV / NumPy pipeline for recorded video that uses per-camera calibration and temporal persistence to detect degradation and emit fault events, annotated video and CSV/JSON reports. No trained model or GPU is required.
Stack: Python · OpenCV · NumPy · pytest · GitHub Actions
Repository · 60-second demo · Evaluation & scope · Engineering design
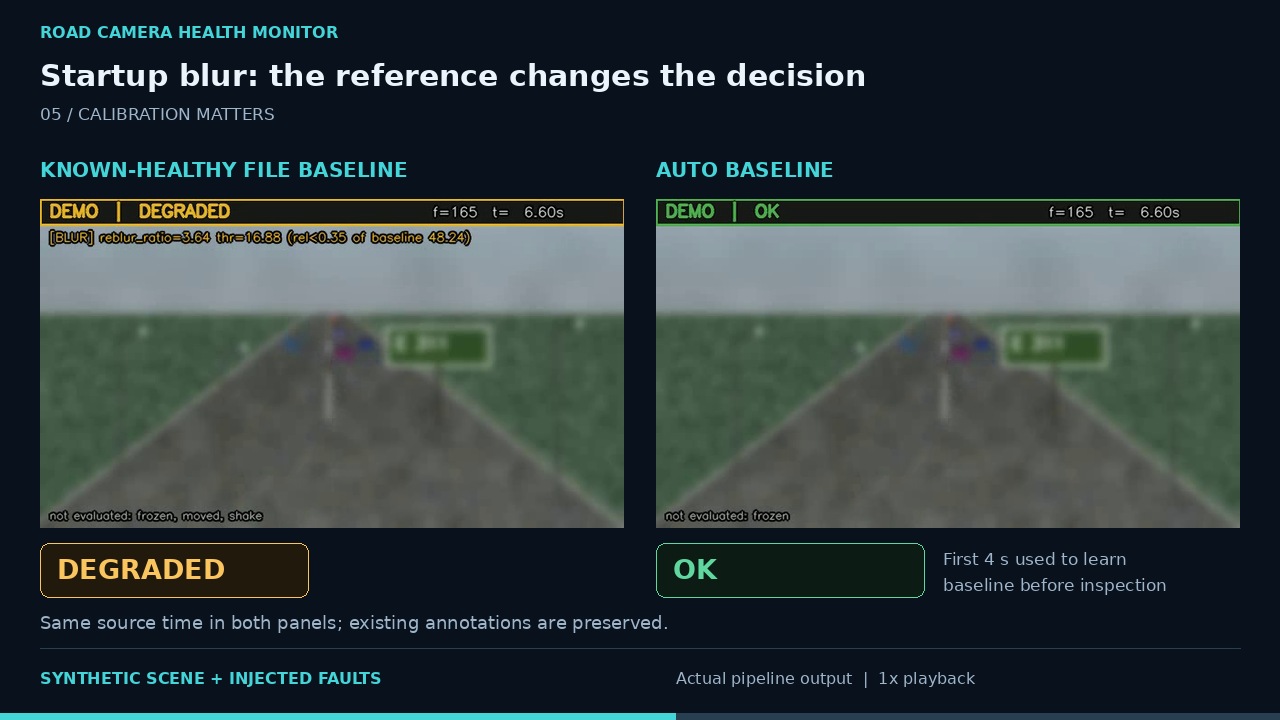
Actual pipeline output on a synthetic scene with injected faults. The demo shows how the calibration reference changes a startup-blur decision.
- Reported synthetic detection: 100% steady-state recall on each target fault clip, after the fault ramp and temporal hold-down, using a known-healthy file baseline.
- Reported clean-clip behavior: 0 false-alarm events on one 16-second synthetic clip.
- Historical container benchmark: 57.6 source frames/s — 2.31× realtime, including annotated-video output, at 640×360 with 25 fps input.
The evaluation uses 11 clips from one generated scene, with thresholds selected on that corpus. These results do not establish field accuracy or target edge-device throughput; real-camera validation remains future work.
Computer Vision & AI Internship · Performise Labs · 2026
Automotive perception prototypes: object detection, drivable-area and lane segmentation, nuScenes camera experiments, PyTorch training/evaluation, knowledge distillation, quantization, ONNX export and model benchmarking. Internship code is not public.
B.Sc. Electrical Engineering and Information Technology · TU Dortmund University, Germany
All B.Sc. degree requirements completed. Available for full-time Junior Computer Vision, Perception and Edge AI roles.
Academic mobile robotics · C++ / ROS
Sequential homing and Pure Pursuit waypoint tracking, with odometry, TF coordinate transforms, velocity control, RViz visualization and transform/timing debugging.
| Area | Tools and practice |
|---|---|
| Computer vision & ML | PyTorch, OpenCV, NumPy, YOLOv8 / YOLO-OBB, object detection, segmentation, knowledge distillation |
| Inference & evaluation | ONNX / ONNX Runtime, FastAPI, mAP evaluation, latency/FPS benchmarking, post-training quantization |
| Software & robotics | Python, C++, Linux, Git, Docker, pytest, GitHub Actions, ROS, TF, RViz |
Germany · Available for full-time junior roles · Open to UAE relocation